Gradient-based Planning for World Models at Longer Horizons – The Berkeley Artificial Intelligence Research Blog
GRASP is a new gradient-based planner for learned dynamics (a “world model”) that makes long-horizon planning practical by (1) lifting
GRASP is a new gradient-based planner for learned dynamics (a “world model”) that makes long-horizon planning practical by (1) lifting
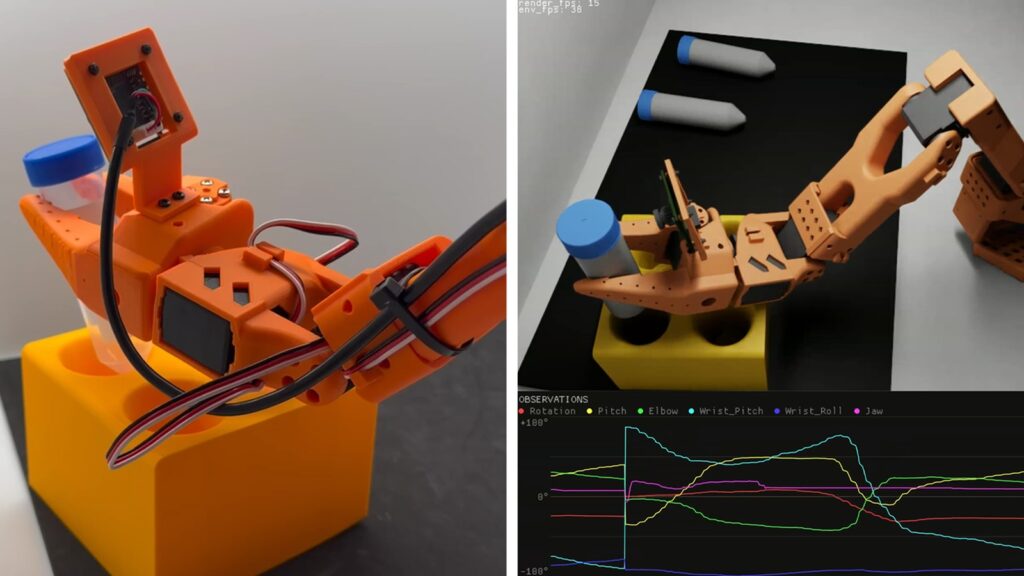
Open source AI has shown how quickly developers can innovate when models, data and tools are shared. Robotics has the
What is the Role of Mathematics in Modern Machine Learning? The past decade has witnessed a shift in how progress
The artificial intelligence coding revolution comes with a catch: it's expensive. Claude Code, Anthropic's terminal-based AI agent that can write,
Synthetic Sciences has released OpenScience, an open-source AI workbench for scientific research. It is licensed under Apache 2.0 and runs
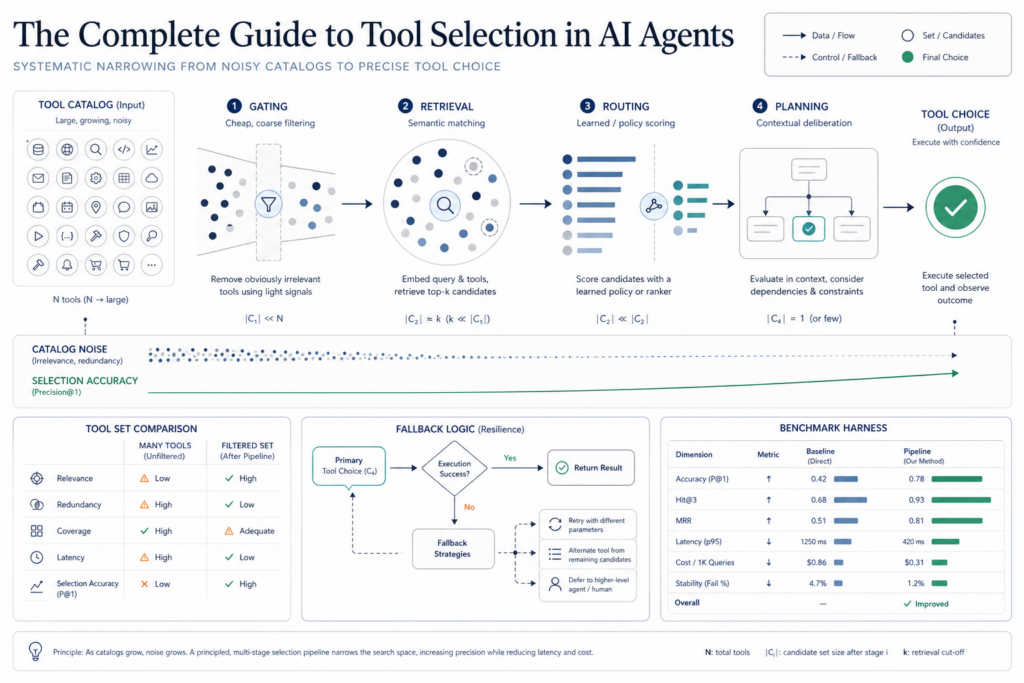
In this article, you will learn why agent accuracy degrades as a tool catalog grows, and six practical techniques for
like Claude Code can be used for a wide variety of tasks. The number one task you might think of
This new release is about closing the robot learning loop: policies that imagine the future before acting, reward models that
Limitations: Omni offers 10-second video generations currently, with longer durations coming soon. Uploading audio references and scene extension is not
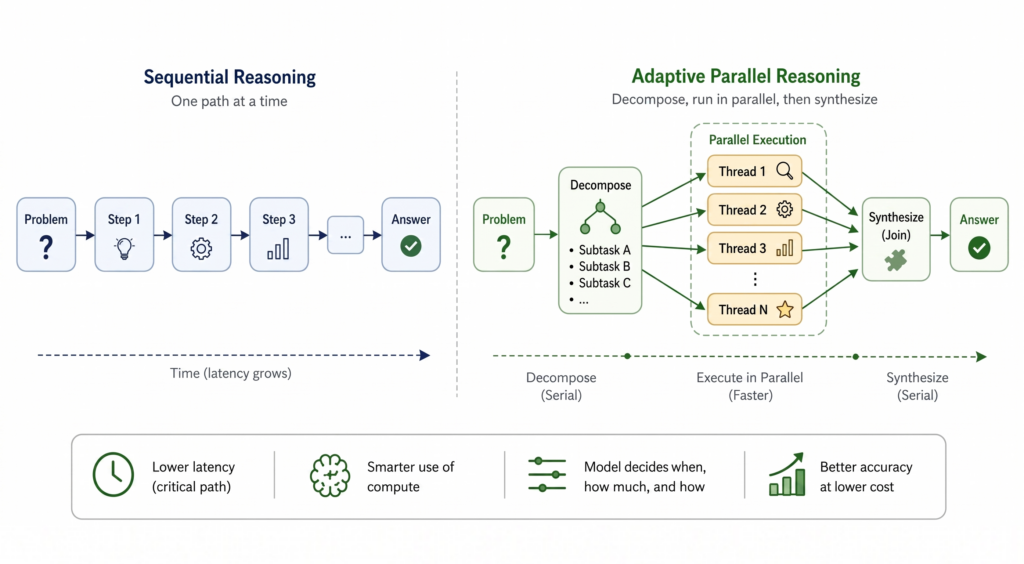
Overview of adaptive parallel reasoning. What if a reasoning model could decide for itself when to decompose and parallelize independent